

What Matters in Quality-Aware VLA Pretraining: A Benchmark and Empirical Study
Paper • 2610.18869 • Published
Error code: JobManagerCrashedError
Need help to make the dataset viewer work? Make sure to review how to configure the dataset viewer, and open a discussion for direct support.
Simulation demonstrations for learning language-conditioned Franka manipulation policies, collected with the AXIS data engine.
Project Website · AXIS-Bench Paper · Code · Documentation · AXIS Data Engine
AXIS is a community-driven robot data engine that collects human demonstrations through browser-based teleoperation and turns them into training data through automated task validation and simulation rendering. This repository hosts per-task Franka demonstration datasets with synchronized third-person and wrist-camera videos, robot observations, action targets, and camera calibration.
The collection supports imitation learning, vision-language-action (VLA) pretraining, and studies of visual and camera variation. The related AXIS-Bench project studies how to use demonstrations of varying quality through weighting, filtering, and quality conditioning, with evaluation in simulation and a workflow for adapting to real robot workspaces.
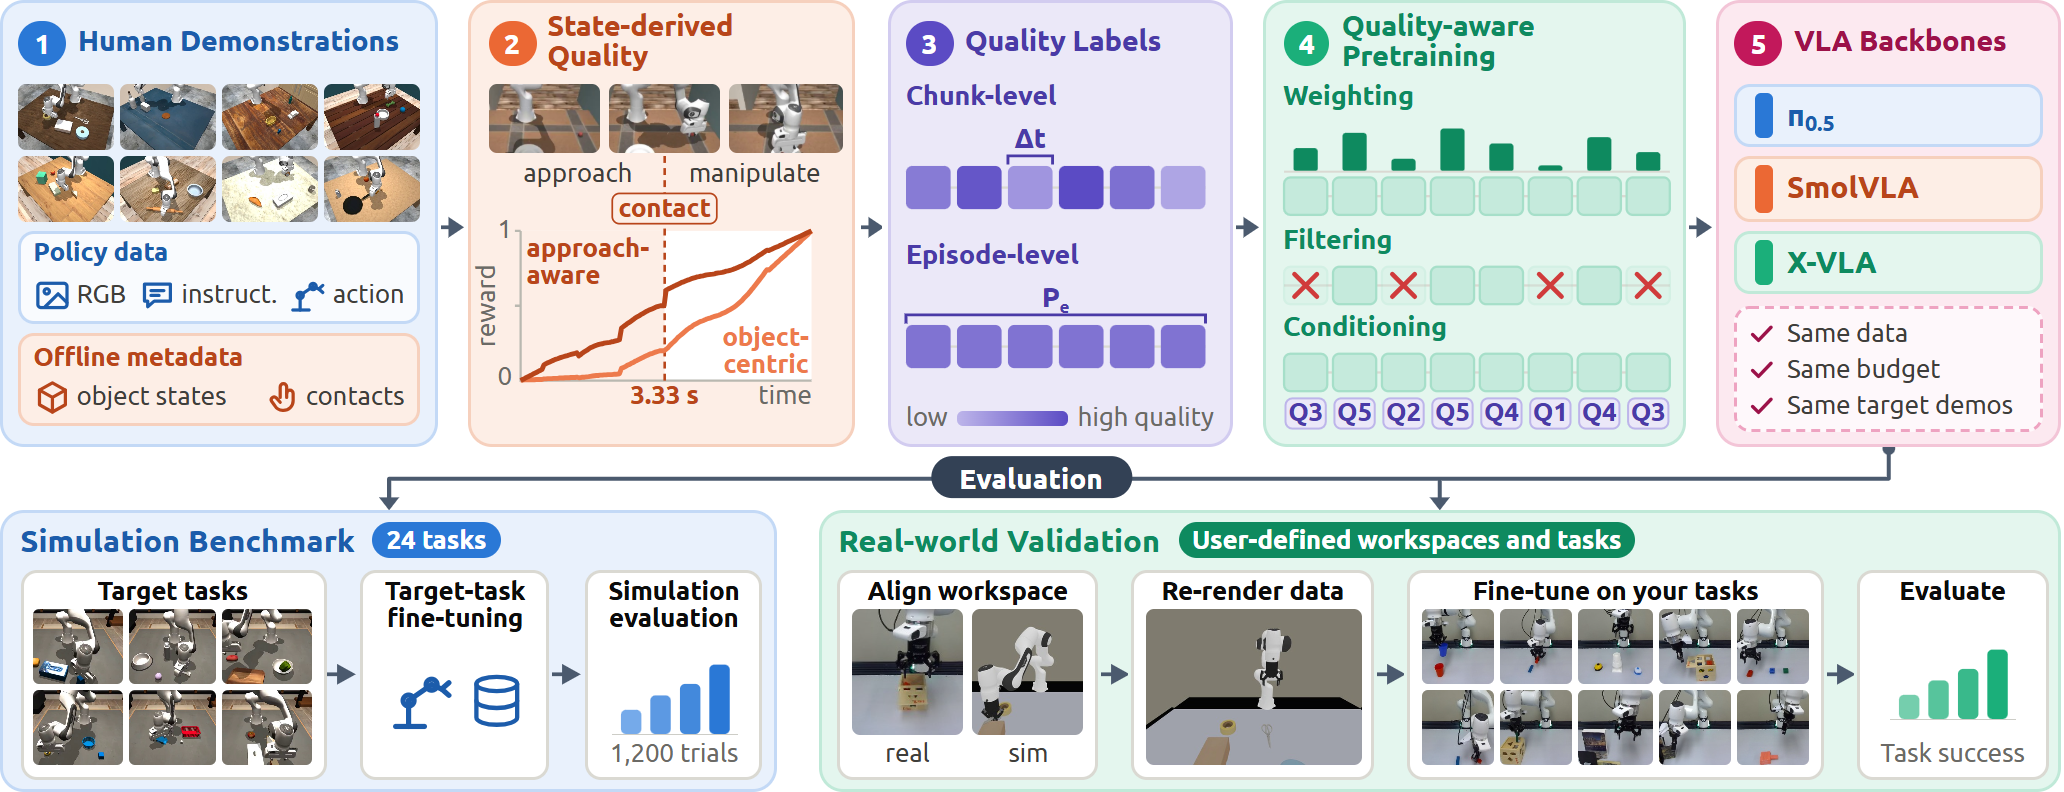
AXIS-Bench workflow from the project website. Its fixed benchmark releases and quality labels are linked below.
| Property | Description |
|---|---|
| Embodiment | Simulated Franka arm and gripper |
| Organization | A separate task directory, with camera_fixed and camera_randomized exports |
| Storage | LeRobot v3.0 layout: Parquet data and episode metadata, JSON metadata, MP4 videos |
| Sampling rate | 15 Hz in the inspected exports |
| Camera views | observation.images.third_person and observation.images.wrist |
| Video format | 640 × 360 RGB, H.264, 15 fps in the inspected exports |
| State and action | 9-dimensional vectors in the inspected exports; see the semantics below |
| Language | Task instructions in meta/tasks.parquet |
Each export's meta/info.json records its exact schema, frame rate, episode/frame counts, and file-path templates. Use these per-export values when selecting data. Camera replicas are additional rendered views of source trajectories; account for their shared provenance when counting demonstrations or creating train/test splits.
Franka-<task_id>-<task_slug>/
├── task_manifest.json
├── camera_fixed/
│   └── task_<task_id>_franka_<task_slug>/
│       ├── data/chunk-000/file-000.parquet
│       ├── meta/
│       │   ├── info.json
│       │   ├── stats.json
│       │   ├── tasks.parquet
│       │   ├── episodes/chunk-000/file-000.parquet
│       │   └── axis_task_dataset.json
│       └── videos/
│           ├── observation.images.third_person/chunk-000/file-000.mp4
│           └── observation.images.wrist/chunk-000/file-000.mp4
└── camera_randomized/
    └── task_<task_id>_franka_<task_slug>/
        └── ...
Some exports also contain meta/axis_episodes/ and meta/axis_attempt_commits/ with episode provenance, rendering details, and camera metadata. Availability varies by export. Consult task_manifest.json and the available episode metadata for source attempt IDs, scene variants, and camera replicas.
camera_fixed and camera_randomized distinguish camera configurations. Both use the same logical image feature names, so data readers can select an export without renaming camera inputs. Parquet and video files are sharded; use the episode metadata to locate episode ranges rather than treating each file as one episode.
The following fields are verified in the fixed and randomized exports of task 1000, “Rotate the Test Tube”; task 1001 also uses the same state/action dimensions. Check meta/info.json and meta/axis_task_dataset.json for the export you use.
| Feature | Shape / type | Meaning |
|---|---|---|
observation.state |
float32[9] |
Actuated joint positions in actuator order: seven arm joints and two finger joints |
action |
float32[9] |
Simulator control vector; recorded action semantics are ctrl |
observation.ee_state |
float32[7] |
End-effector state vector; consult the export's metadata for its convention |
observation.images.third_person |
Video, 360 × 640 × 3 |
External camera view |
observation.images.wrist |
Video, 360 × 640 × 3 |
Wrist camera view |
observation.cameras.<view>.intrinsics |
float32[9] |
Row-major flattened 3 × 3 camera intrinsics |
observation.cameras.<view>.camera_to_world |
float32[16] |
Row-major flattened 4 × 4 camera-to-world transform |
timestamp |
float32[1] |
Frame timestamp |
frame_index, episode_index, index, task_index |
int64[1] each |
Frame, episode, row, and instruction indexing |
Here <view> is third_person or wrist. The inspected camera metadata specifies the MuJoCo/OpenGL camera frame: +X points image-right, +Y points up, and −Z points forward, transformed into world coordinates.
Training configuration: the 9-D simulator controls here require the corresponding controller conventions. AXIS-Bench's prepared DROID-compatible 8-D training data is distributed separately in qvla-v1-corpus; use that release and its recipes to reproduce the paper.
Install the Hub client:
pip install -U huggingface_hub
This downloads a small JSON file before fetching videos or data shards:
import json
from pathlib import Path
from huggingface_hub import hf_hub_download

repo_id = "axisrobotics/Franka-Datasets-v2"
export = (
    "Franka-1001-rotate_the_pipette/camera_fixed/"
    "task_1001_franka_rotate_the_pipette"
)
info_path = hf_hub_download(
    repo_id=repo_id,
    repo_type="dataset",
    filename=f"{export}/meta/info.json",
)
info = json.loads(Path(info_path).read_text())
print(info["fps"], info["total_episodes"], info["total_frames"])
print(info["features"])
The full repository is multi-terabyte. Start with one export using an include pattern:
hf download axisrobotics/Franka-Datasets-v2 \
  --repo-type dataset \
  --include "Franka-1001-rotate_the_pipette/camera_fixed/**" \
  --local-dir ./franka-datasets-v2
The local dataset root is then:
./franka-datasets-v2/Franka-1001-rotate_the_pipette/camera_fixed/task_1001_franka_rotate_the_pipette
Use a LeRobot v3-compatible reader with this local root, preserving the data/, meta/, and videos/ directories. Select camera_randomized in the include pattern to download that configuration. Add --revision <commit_sha> to pin a download for reproducible experiments. See the Hugging Face download guide for Python downloads and filtering options.
The AXIS-Bench paper uses selected, processed data under a fixed protocol. Its simulation study uses 5,000 pretraining demonstrations across 731 tasks and evaluates on 24 target tasks. The real-world experiment pretrains on 19,250 simulation demonstrations before fine-tuning on real robot data. These are experiment-specific subsets, rather than totals for this repository.
| Repository | Contents |
|---|---|
| qvla-v1-corpus | Prepared pretraining data, frame indexes, quality labels, and training weights |
| qvla-v1-bench | Target-task demonstrations, scene assets, success checkers, and evaluation layouts |
| qvla-v1-realworld | Replayable simulation trajectories and scene records for workspace-aligned pretraining |
| qvla-v1-results | Published rollout logs and results |
Follow the code and training recipes and data documentation for the tagged v1.0 benchmark release, quality-label computation, training, and evaluation.
train range in meta/info.json describes the local export and does not define the paper's held-out evaluation protocol.A dataset license has not yet been specified in this repository. Please contact Axis Robotics for dataset licensing information. The AXIS-Bench code, website, and separately released datasets state their own licenses.
For the AXIS data engine:
@article{zhao2026axis,
  title={AXIS: A Growable Community-Driven Data Engine for Scalable Robot Manipulation},
  author={Zhao, Mengfei and Huang, Dihong and Tang, Yikai and Li, Peihao and Yan, Mingxuan and Zhuang, Ruiqi and Huang, Yanjia and Wang, Jie and Zhai, Hai and Zhou, Tony and others},
  journal={arXiv preprint arXiv:2607.21588},
  year={2026}
}
For quality-aware VLA pretraining and AXIS-Bench:
@article{yan2026matters,
  title={What Matters in Quality-Aware VLA Pretraining: A Benchmark and Empirical Study},
  author={Yan, Mingxuan and Gong, Litian and Huang, Dihong and Li, Zhixu and Zhang, Tianyu and Zhang, Wenqian and Jiang, Hefeifei and Li, Peihao and Zhang, Jian and Zhao, Mengfei and others},
  journal={arXiv preprint arXiv:2610.18869},
  year={2026}
}
For questions about this dataset, open a discussion on this repository. For AXIS-Bench code and reproduction questions, use the GitHub issue tracker.